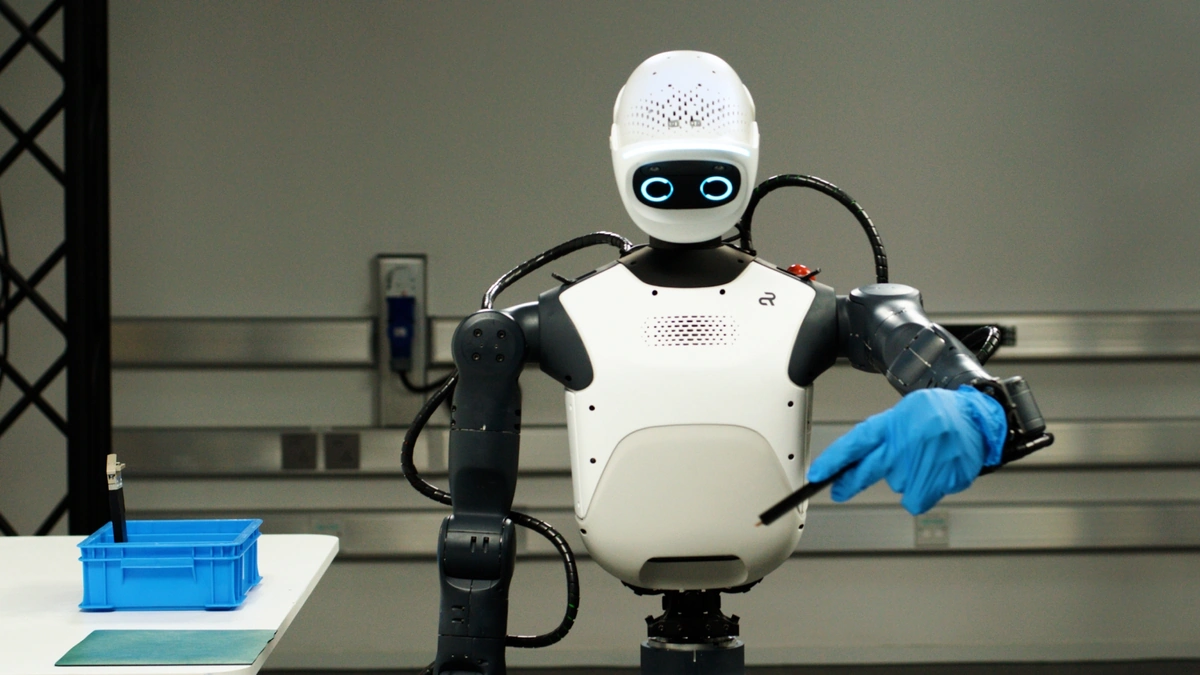
The NVIDIA Isaac platform now covers a reference humanoid, an open source runtime and a new major version of its robot-learning framework, all introduced at GTC Berlin. Isaac Lab 3.0 is generally available, while the humanoid is not due until early 2027.
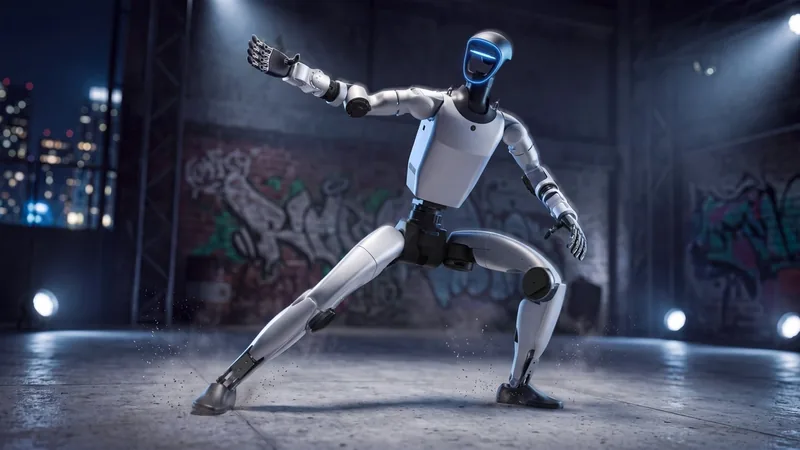
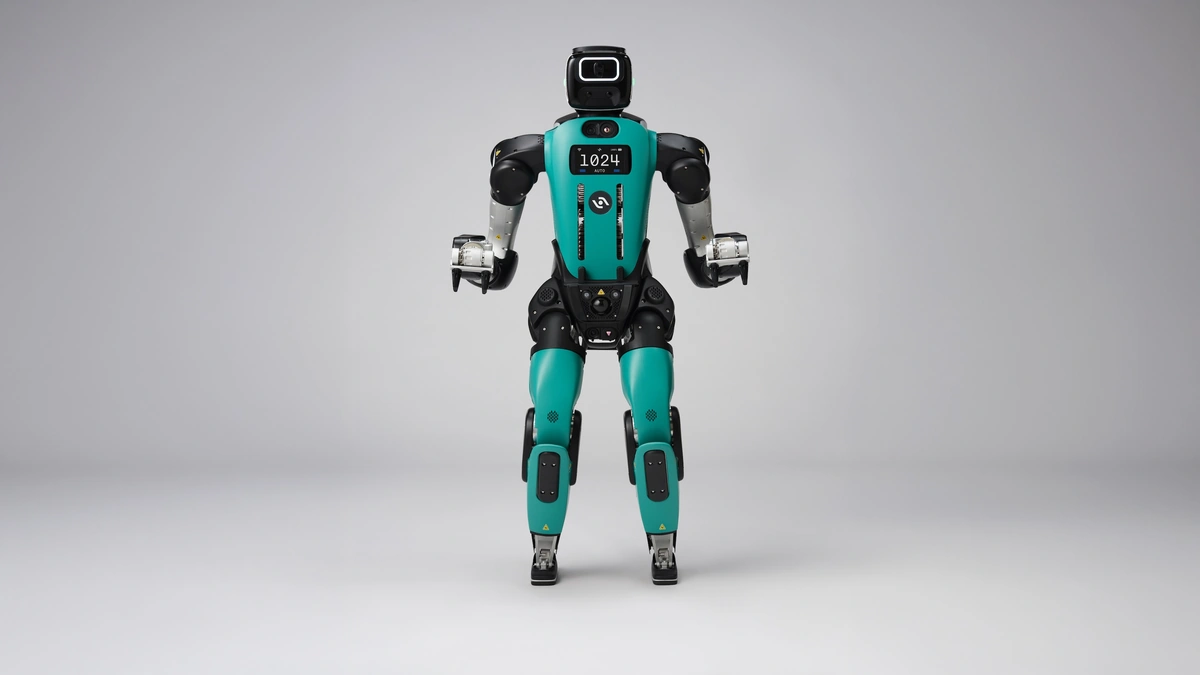
The humanoid is Agile ONE SN from Agile Robots, preconfigured with Isaac GR00T and driven by a Jetson Thor computer. NVIDIA describes a machine about 1.40 meters (4.59 feet) tall with 31 degrees of freedom. It weighs 40 kilograms (88 pounds) and has a 3-kilogram payload per arm. Its two five-finger hands each offer 20 degrees of freedom, 1 kHz force control and tactile sensing.
The Jetson Thor module handles reasoning and real-time control on the robot itself, rated at 2,070 FP4 teraflops with 128GB of unified memory. NVIDIA says putting the simulation, training and deployment tools on one platform cuts setup time from weeks to days, and it names Stanford University and ETH Zurich among the institutions interested. Linking the robot's safety protocols to NVIDIA's Halos system is still a plan.
On the software side, Isaac Lab 3.0 is the Isaac platform's open source framework for training robot policies across multiple GPUs, with physics engines including Newton and PhysX. For Isaac Lab across versions, NVIDIA says the framework also works with Warp and MuJoCo, handles both imitation and reinforcement learning, and runs headless from a workstation up to a data center. NVIDIA also calls Isaac Lab the foundational robot-learning framework of the GR00T platform, which the new humanoid comes preconfigured with.
Isaac OS, the other software addition, is an open source runtime built on NVIDIA Holoscan that ties AI models, sensors, controls and robot hardware together with deterministic, real-time behavior from simulation to the physical machine. NVIDIA lists the robotics company Humanoid among its users, pairing it with Jetson Thor, Holoscan Sensor Bridge and Halos to validate robot behaviors before industrial pilots.
A new library called SimReady Central offers over 2,000 ready-to-simulate robot and factory assets. The Human 1M Dataset covers diverse human activities, with synchronized three-view video and 3D hand tracking. Both are hosted on Hugging Face, though the complete Human 1M Dataset is limited to Cosmos Coalition partners. Three open source reference workflows for DGX Station cover refining GR00T models with reinforcement learning, training dexterous manipulation in Isaac Lab and post-training Cosmos world models for synthetic data with ChatGPT Astra. 1X, Skild AI, Sereact and others will support them.
Agility, Dexory, FORT Robotics and KION are integrating NVIDIA's Halos safety system for warehouse robots, and SICK is evaluating it for dynamic safety that lets industrial robots respond to changing conditions beyond fixed zones. Toyota Material Handling Europe and SoftServe, building material-handling systems on Omniverse and Isaac Sim, are credited by NVIDIA with deployment times cut by up to 50 percent. Bellboy's Billie robot, built on Jetson and GR00T, already operates in hotels run by Marriott, Hilton, IHG and OYO.